I believe the task is **completed**.
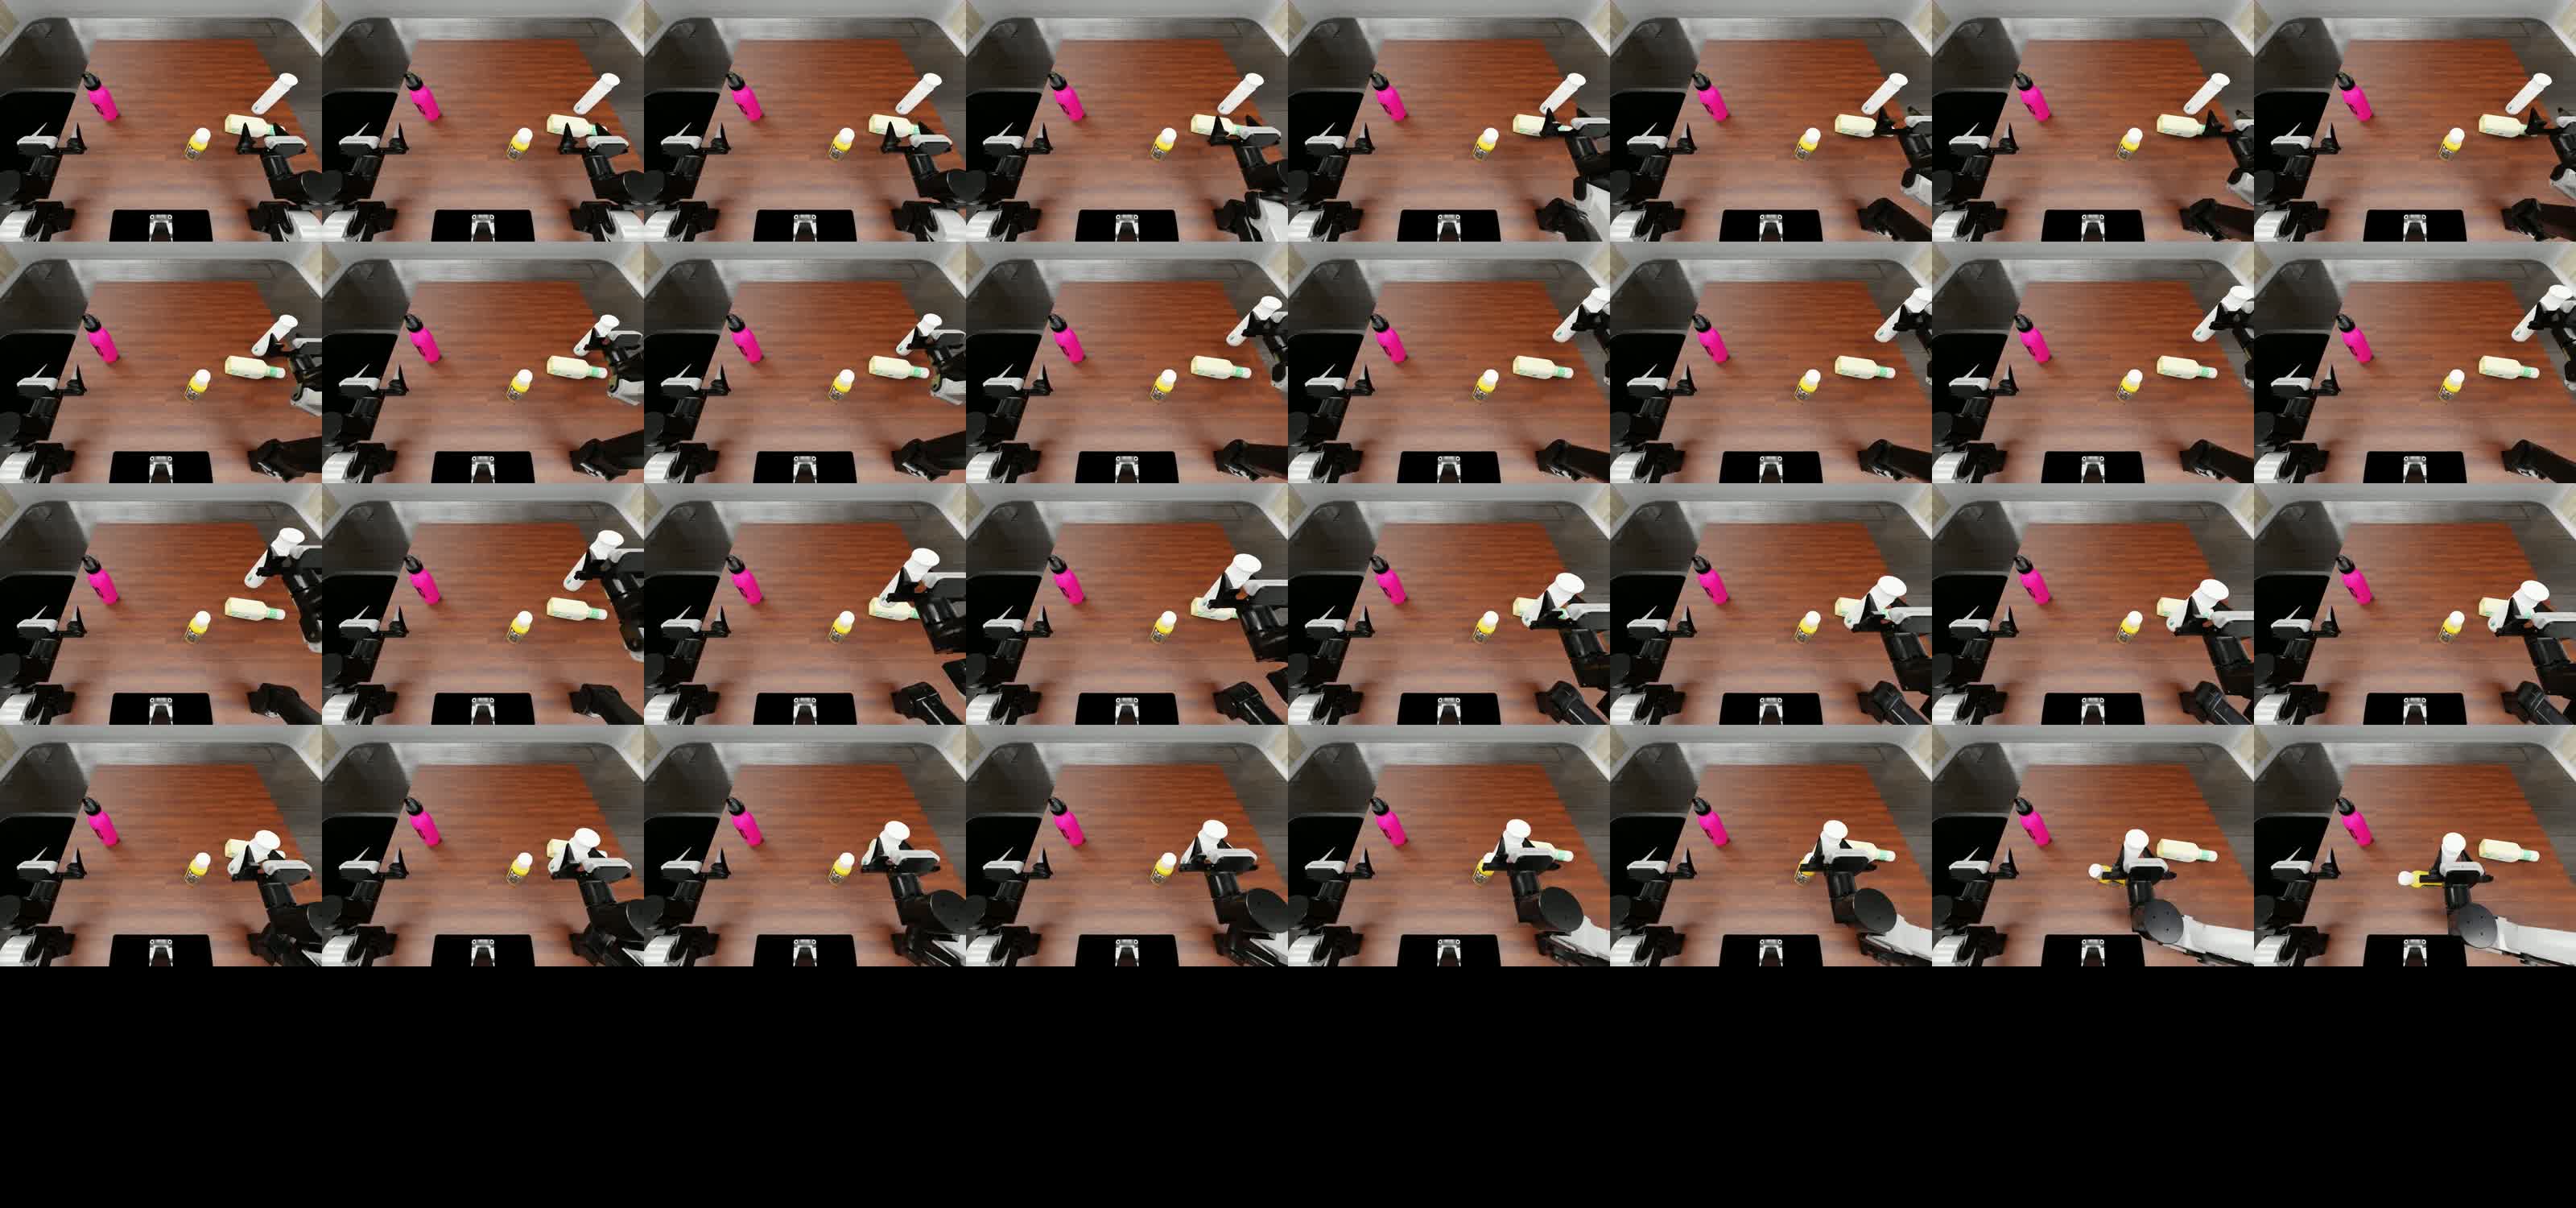
The right arm grasped the tall white bottle and lifted it approximately 10 cm off the table. The camera views showed the bottle retained between the right gripper’s fingers. I then moved it beside the smaller yellow bottle and performed a lateral strike.
After that motion, the yellow bottle had moved to the left and was lying on its side; it had been upright beforehand. The white bottle remained held in the right gripper, and the action feedback confirmed that the striking motion completed. These observations support my judgment that the held bottle struck the other bottle.
This is my self-assessment from the camera observations and action feedback, not an independent success evaluation.
Used the right arm to lift the white bottle and strike the pale bottle, which visibly moved after contact. Released the white bottle and returned both arms home with grippers open.
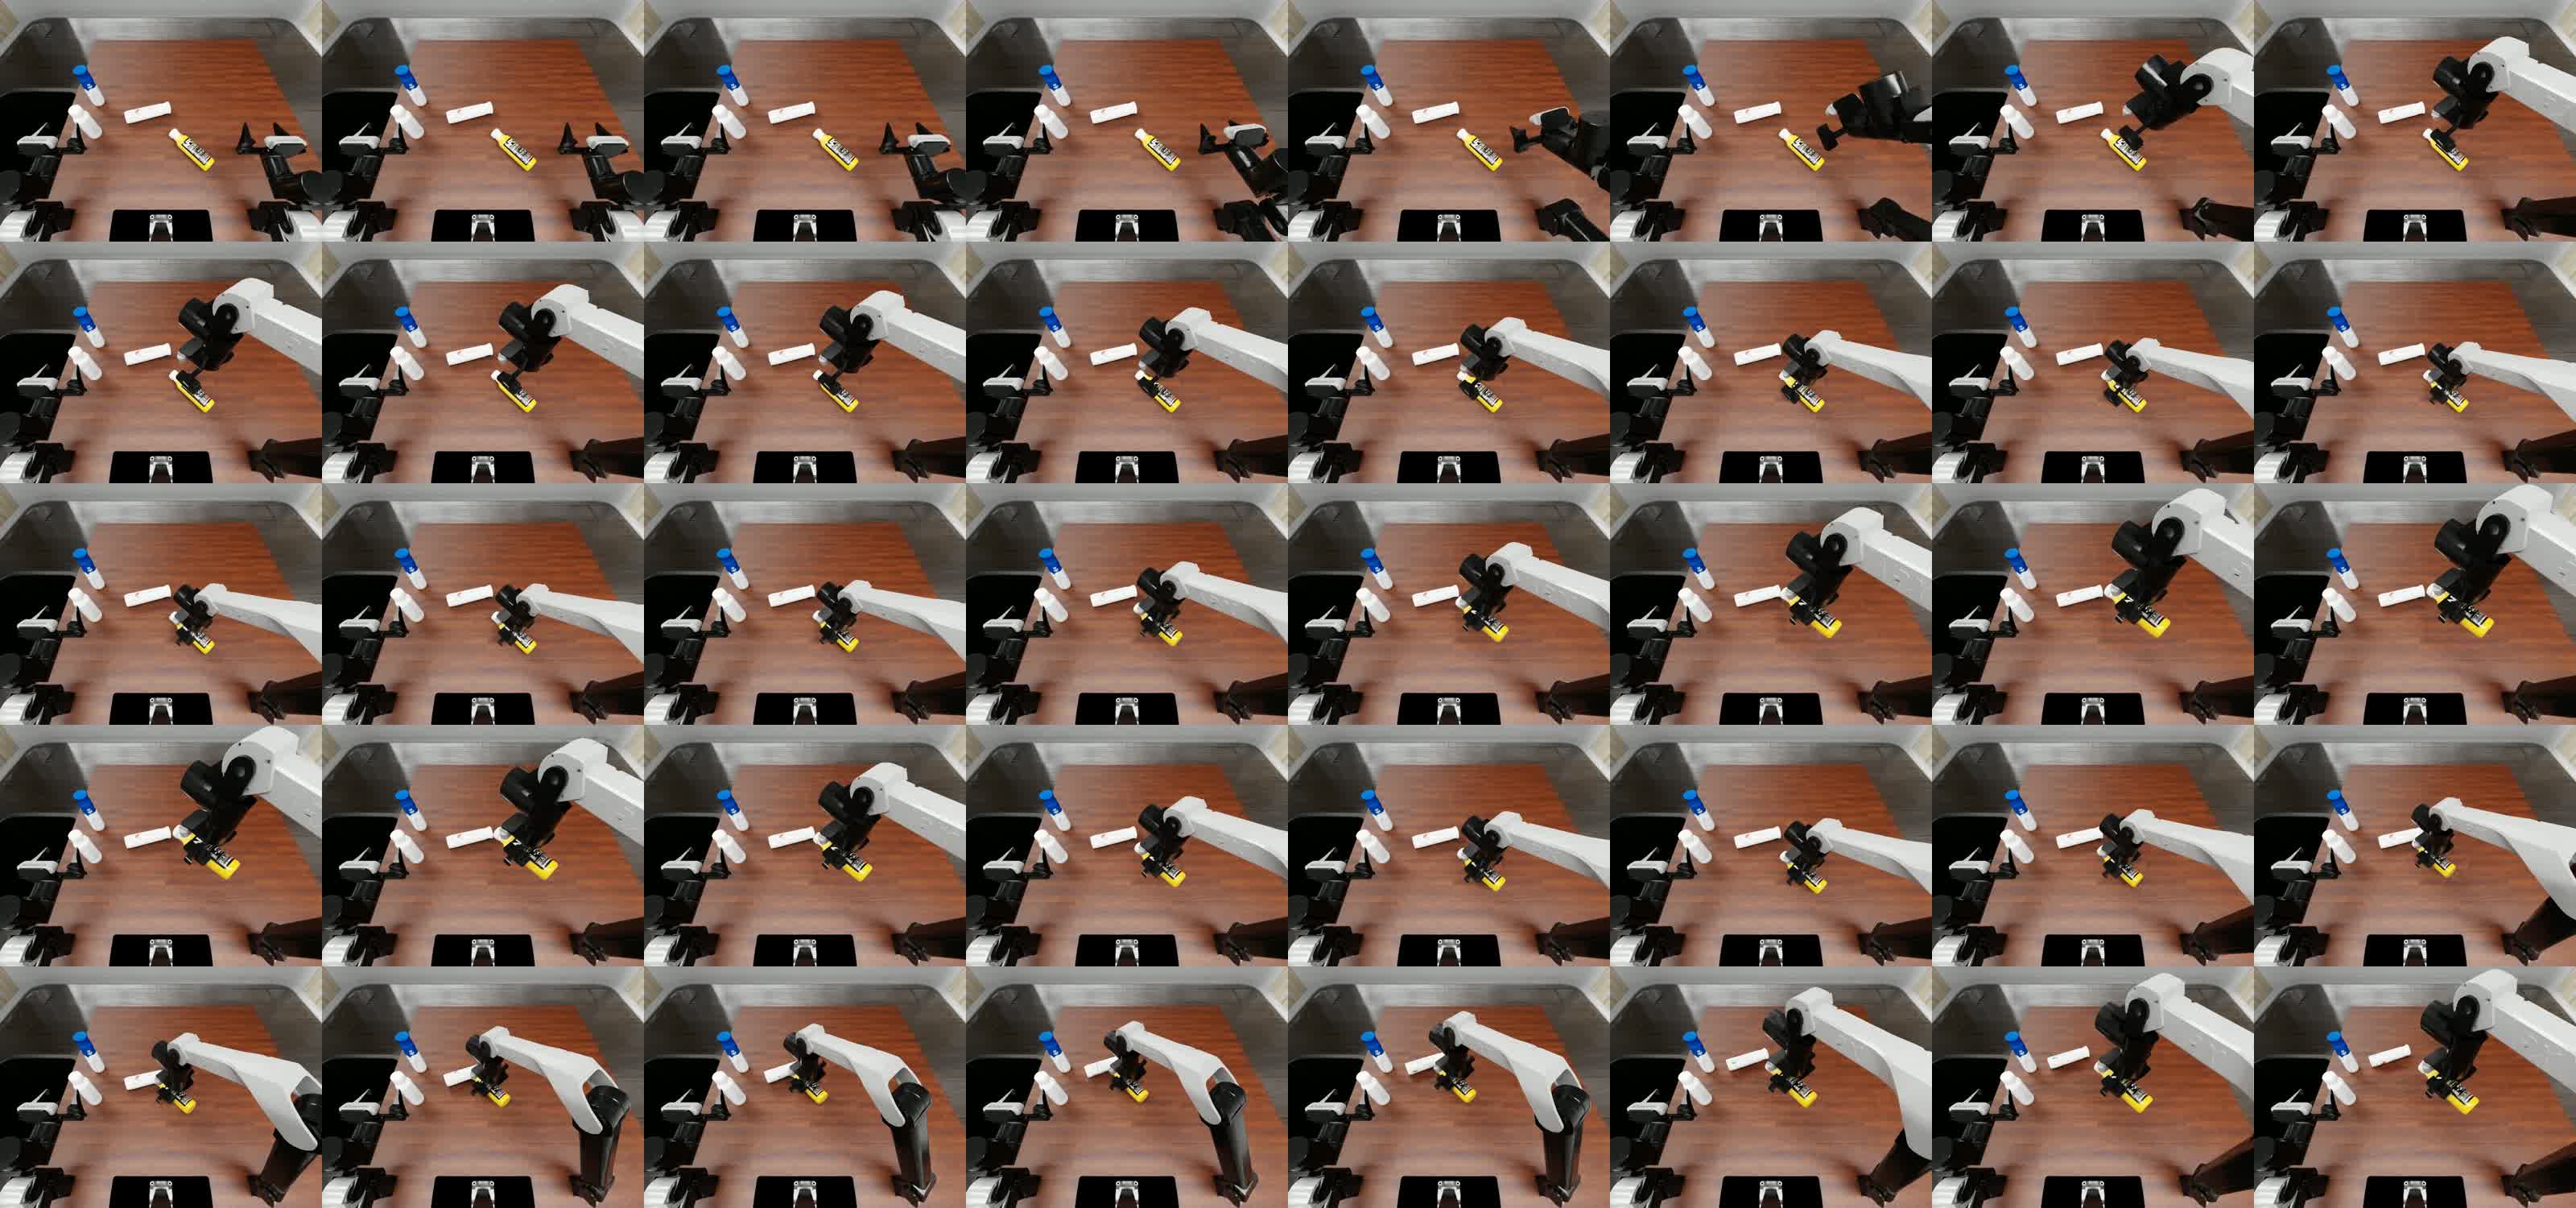
**I believe the task is completed.** The right arm picked up the yellow bottle, visibly lifted it off the table, and used its exposed capped end in a short striking motion toward the white bottle lying near the centre.
After the strike, the white bottle had visibly moved farther back and to the left and changed orientation. The yellow bottle remained held in the right gripper during withdrawal. The action feedback reported that the lift, strike, and withdrawal motions completed.
This is my self-assessment based on the observed bottle movement and action feedback, not an independent success evaluation.
The right arm picked up the yellow bottle and struck the white bottle with it, visibly displacing the white bottle. The yellow bottle was set back on the table, and both arms returned home with open grippers.
I believe the task is **completed**.
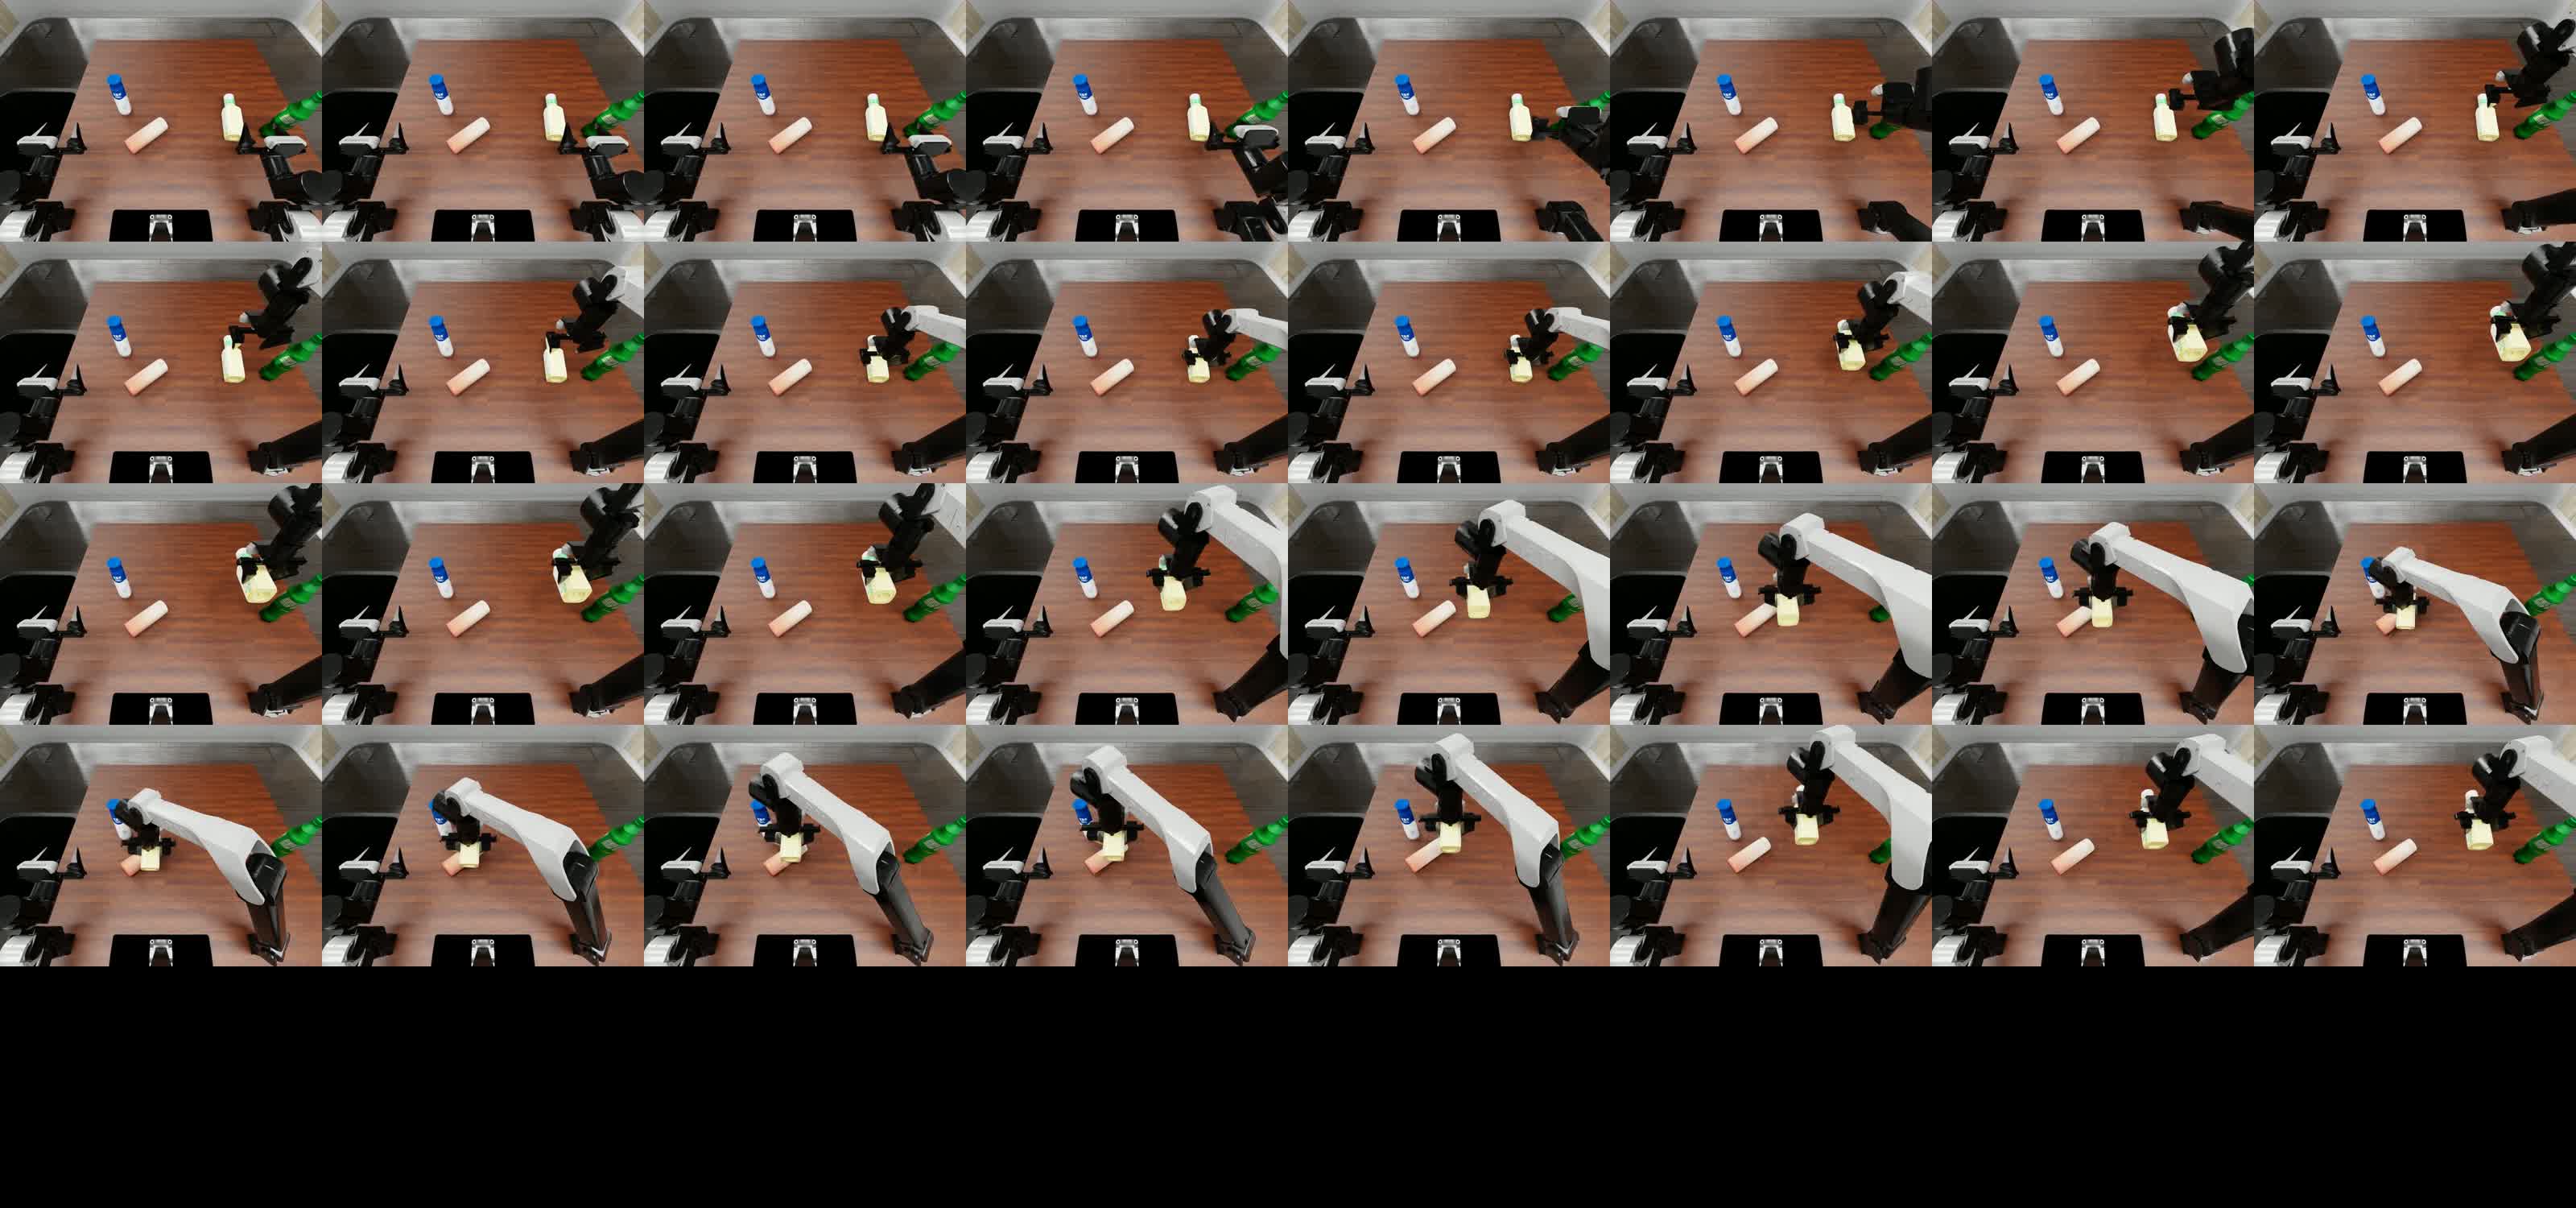
The right arm picked up the pale yellow bottle and visibly lifted it clear of the table. I then used it to deliver a short downward, diagonal strike against the pink bottle. The contact image showed the yellow bottle against the pink bottle, and the motion feedback reported the arm ending about 17 mm above its requested height, consistent with resistance during contact.
After I lifted and withdrew the right arm, the pink bottle was visibly displaced to the left of its original position. The yellow bottle remained held in the right gripper. These observations support my assessment that the held bottle struck the other bottle; this is my self-assessment, not an independent success evaluation.
The right arm picked up the pale yellow bottle and struck the pink-and-white bottle with it, with contact indicated by the stopped downward motion. The held bottle was then set down and both arms returned home with open grippers.
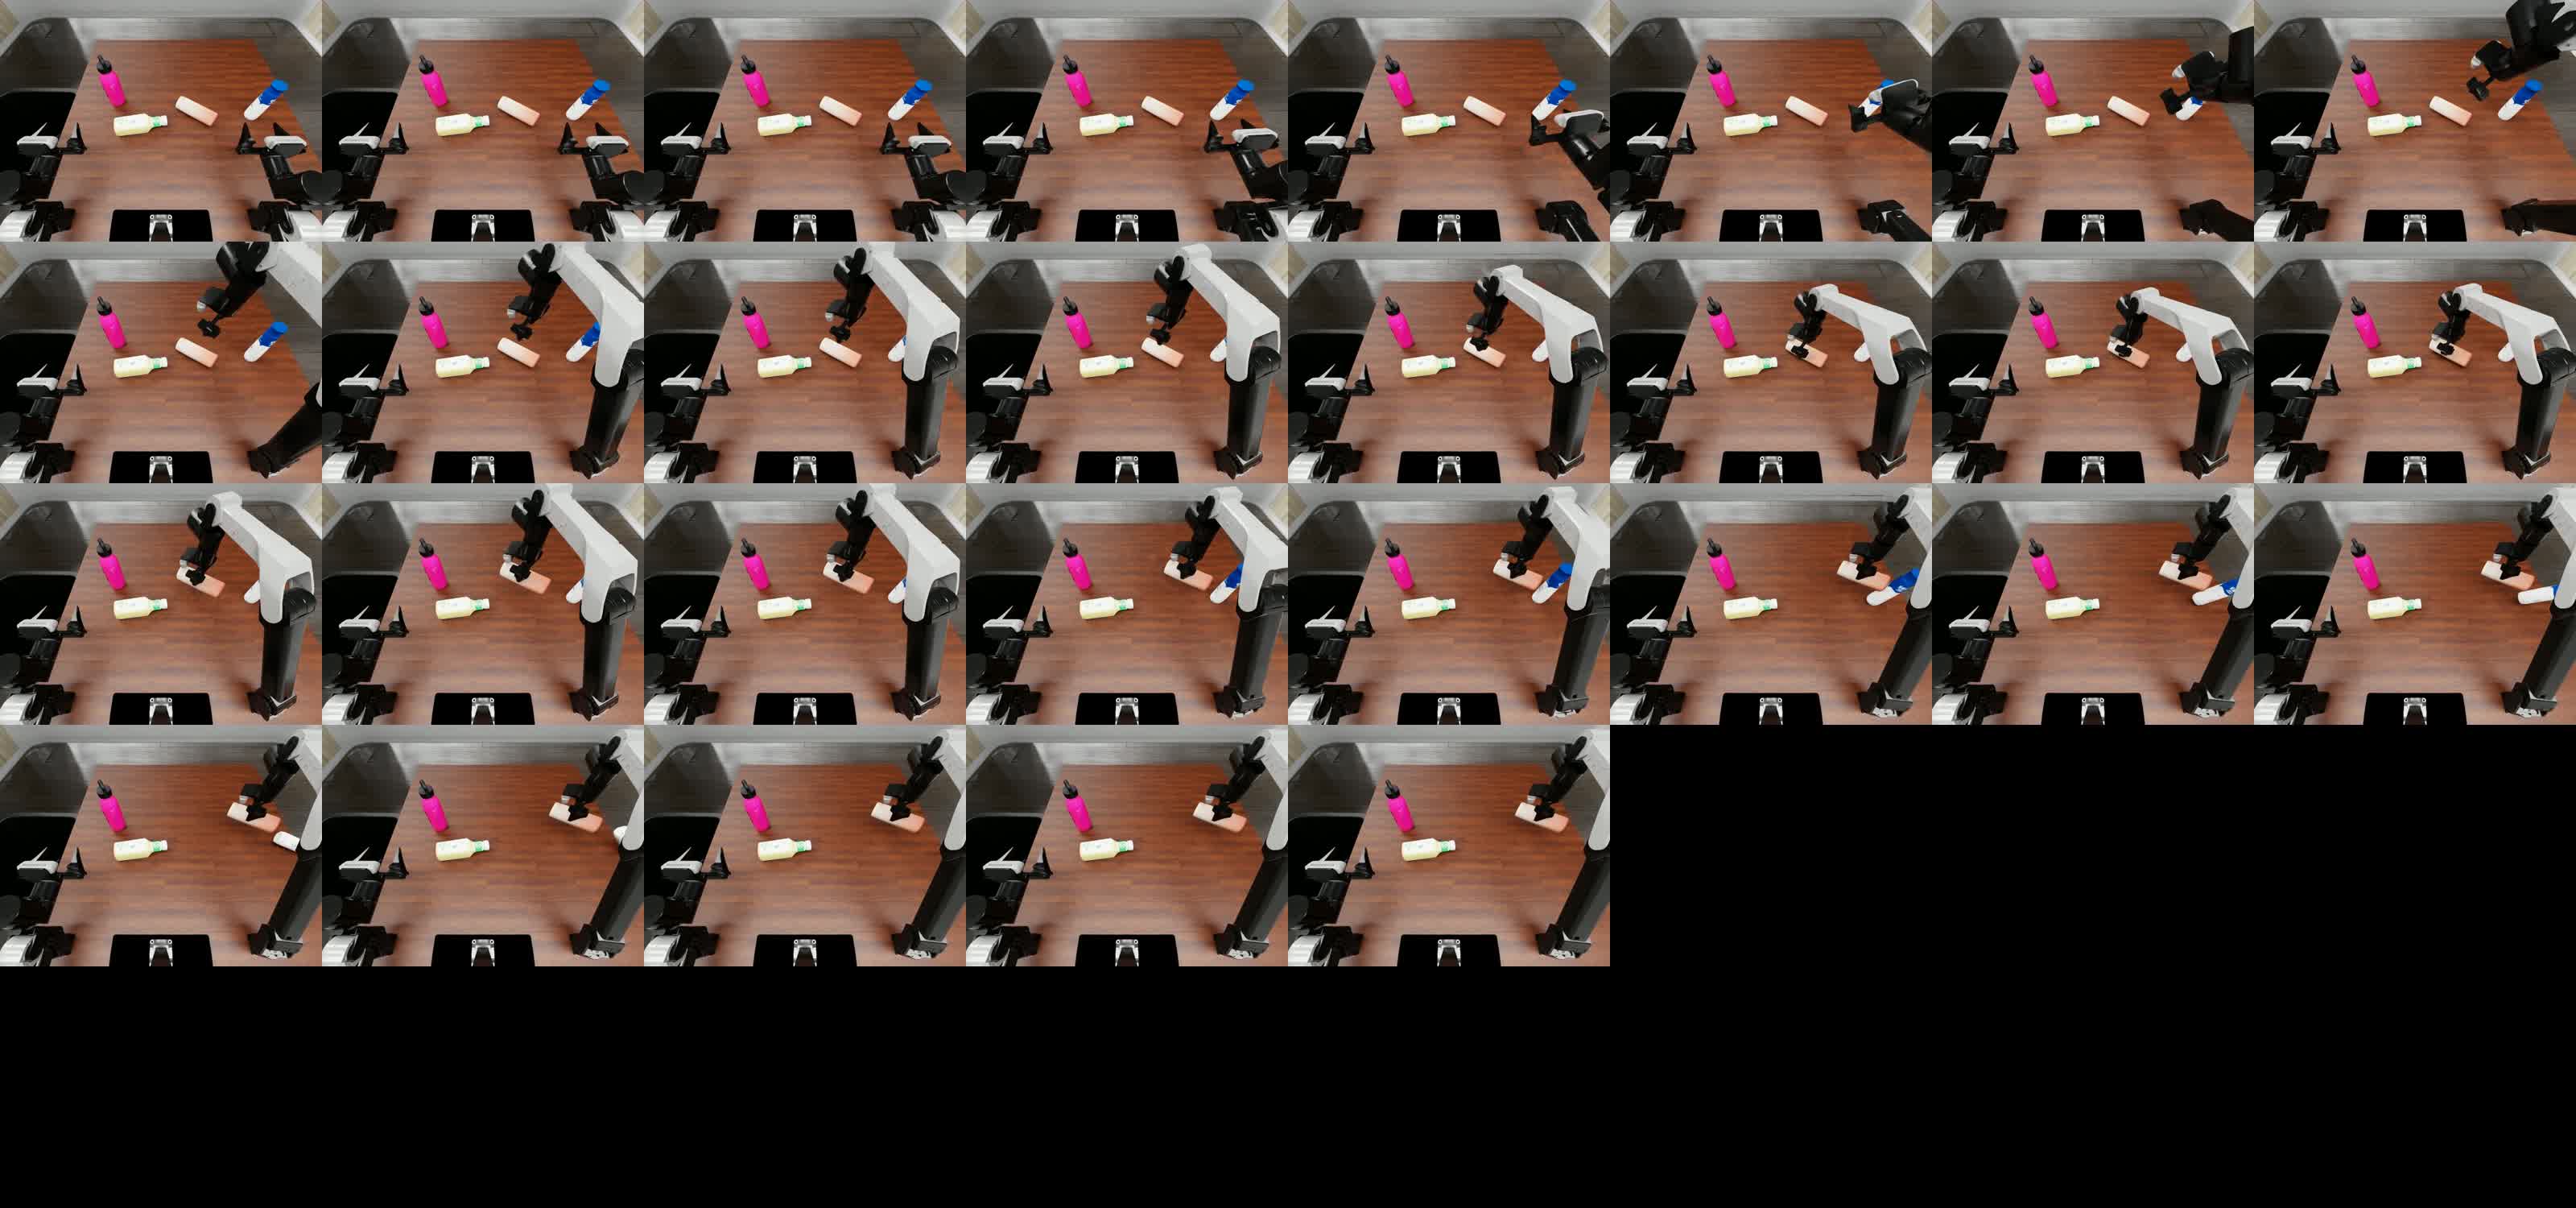
**I believe the task is completed.** The right arm picked up the peach-colored bottle, lifted it clear of the table, and retained it while making a rightward striking motion into the blue-and-white bottle.
Immediately after the stroke, the blue-and-white bottle was visibly displaced and tilted to the right. While the arm then held still, that bottle continued moving out of the tabletop camera view. The peach bottle remained visibly grasped in the right hand.
This is my self-assessment based on the observed bottle movement and action feedback, not an independent success evaluation.
The right arm picked up the peach bottle and struck the blue-and-white bottle, visibly displacing it. The held bottle was released onto the table and both arms returned home with open grippers.